 ™
Complementary robots. Coordinated missions.
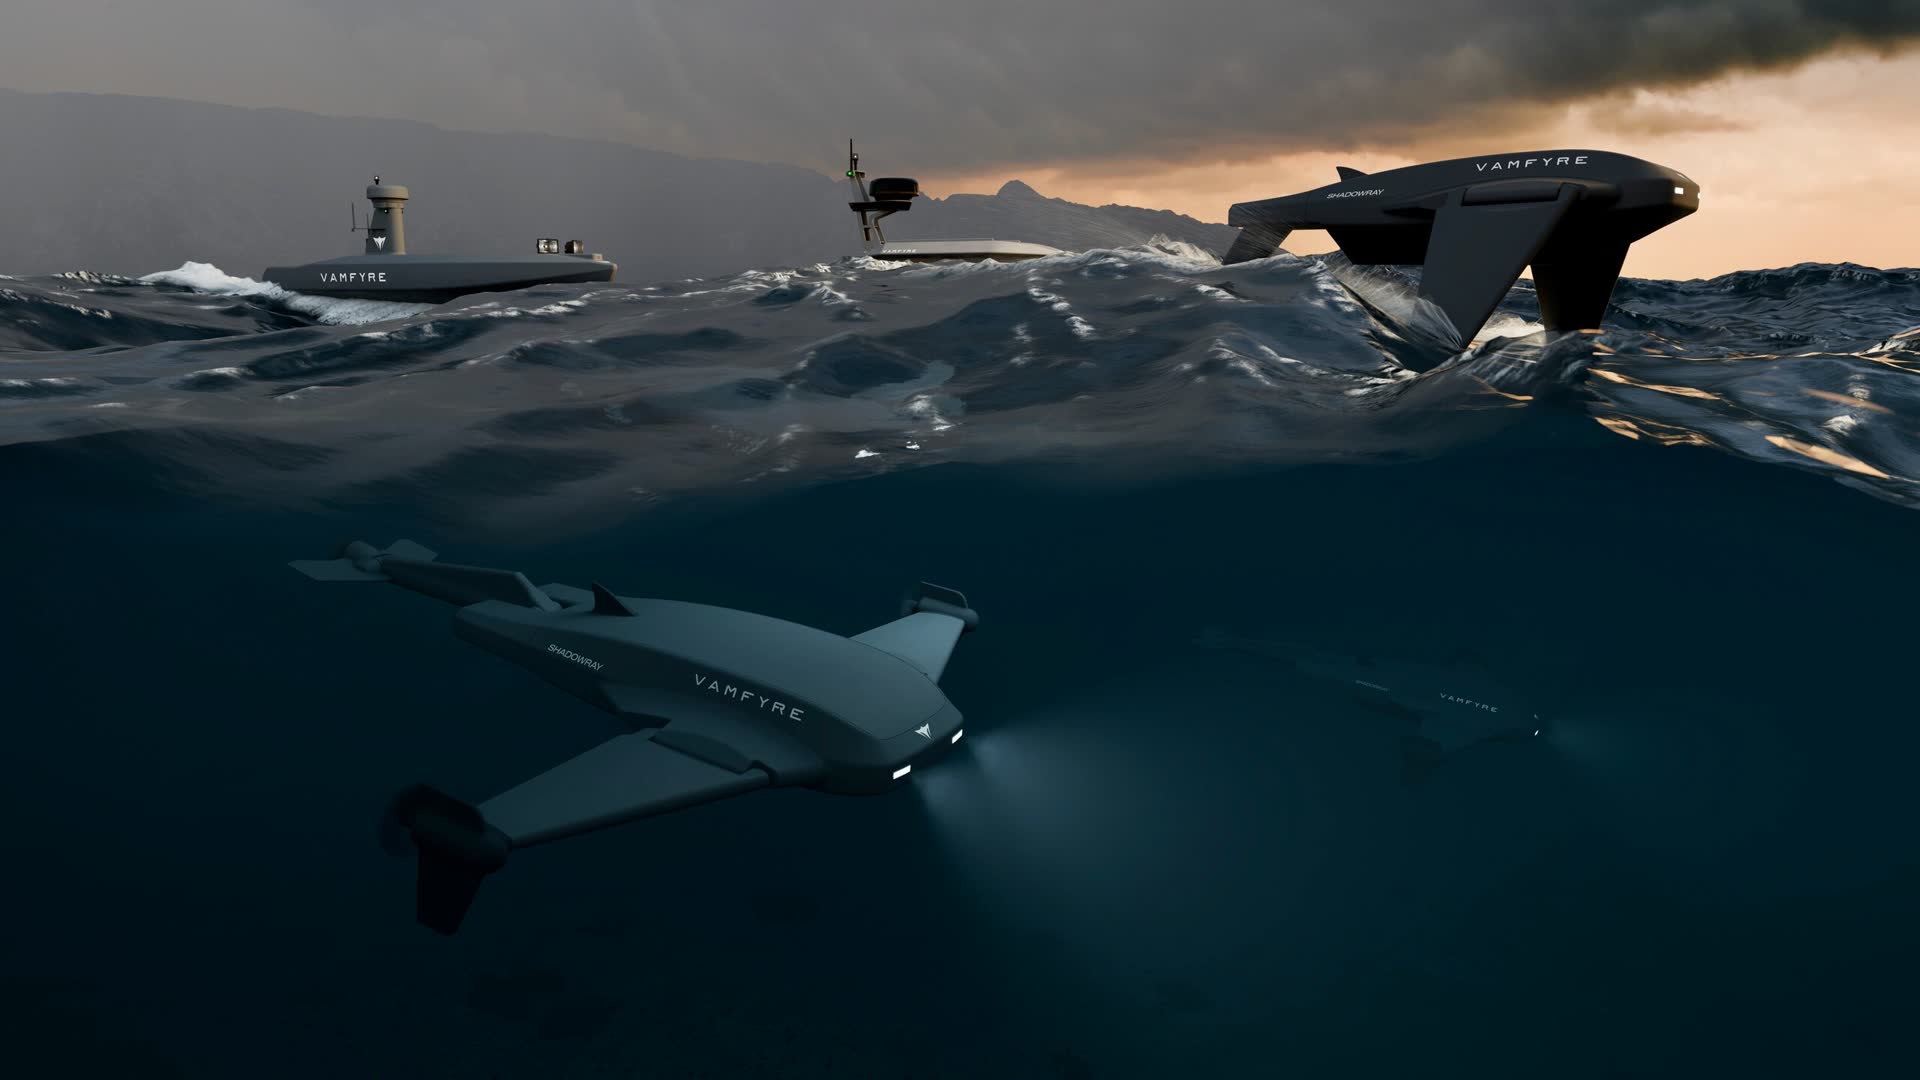
ShadowRay, ShadowDart, and ShadowHawk are designed to cover surface, subsurface, and air, coordinated through POSEIDON.
In developmentThe fleet
Each vehicle has a job in the mission.
 |
 |
 |
|
|---|---|---|---|
| Job | Surface, foiling, and subsurface operation in one hull | Sustained surface sensing and communications relay | Extended aerial surveillance |
| Domain | Surface, foiling, and subsurface | Surface | Air |
| Length | 5 m | 2.2 m | Multirotor drone |
| Design payload | 100 kg | 150 kg | Surveillance payload |
| Energy | Electric | Electric, with solar and wave energy harvesting | Battery electric |
Design values; mission configuration dependent.
In developmentSurface. Foil. Dive.
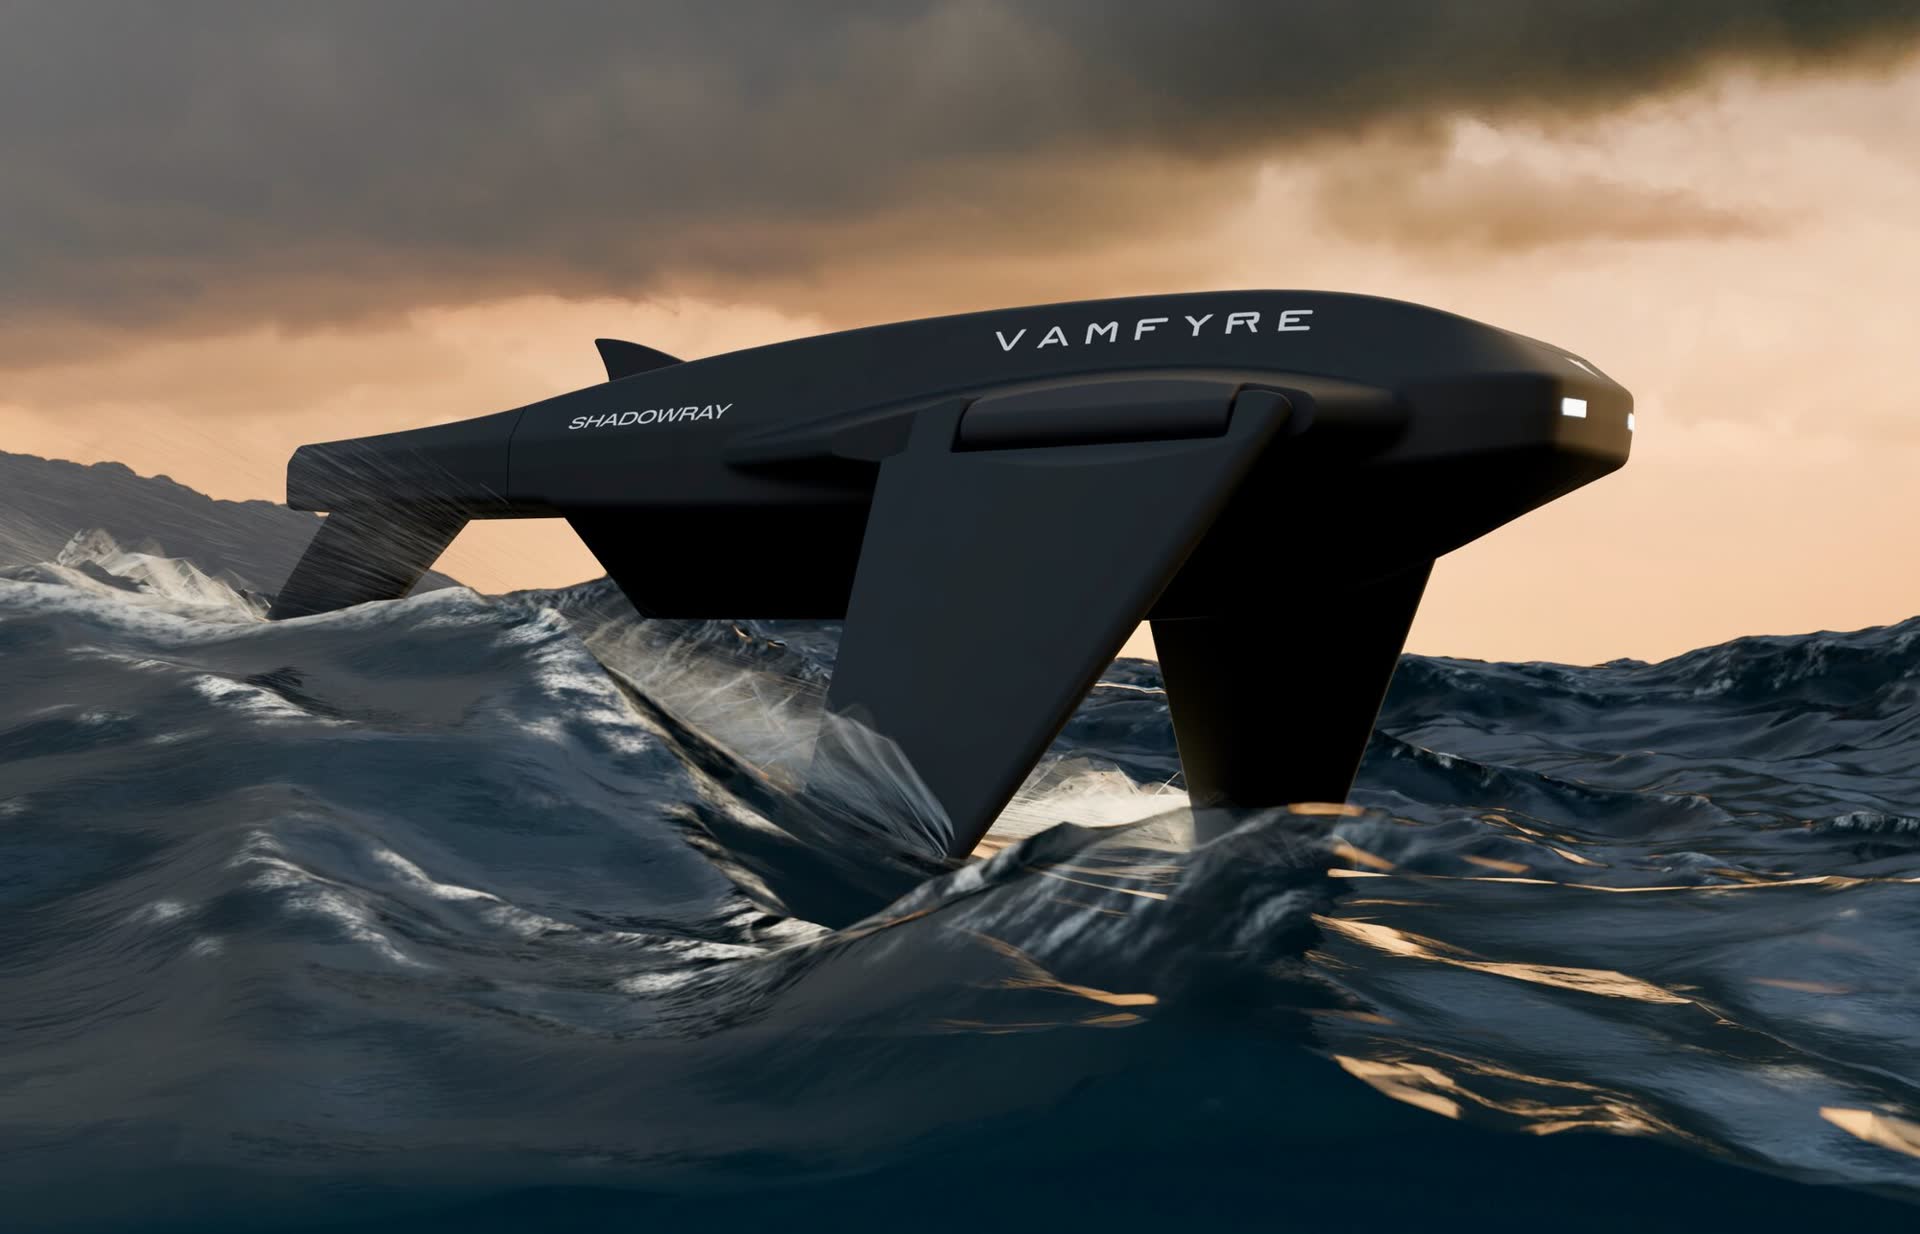
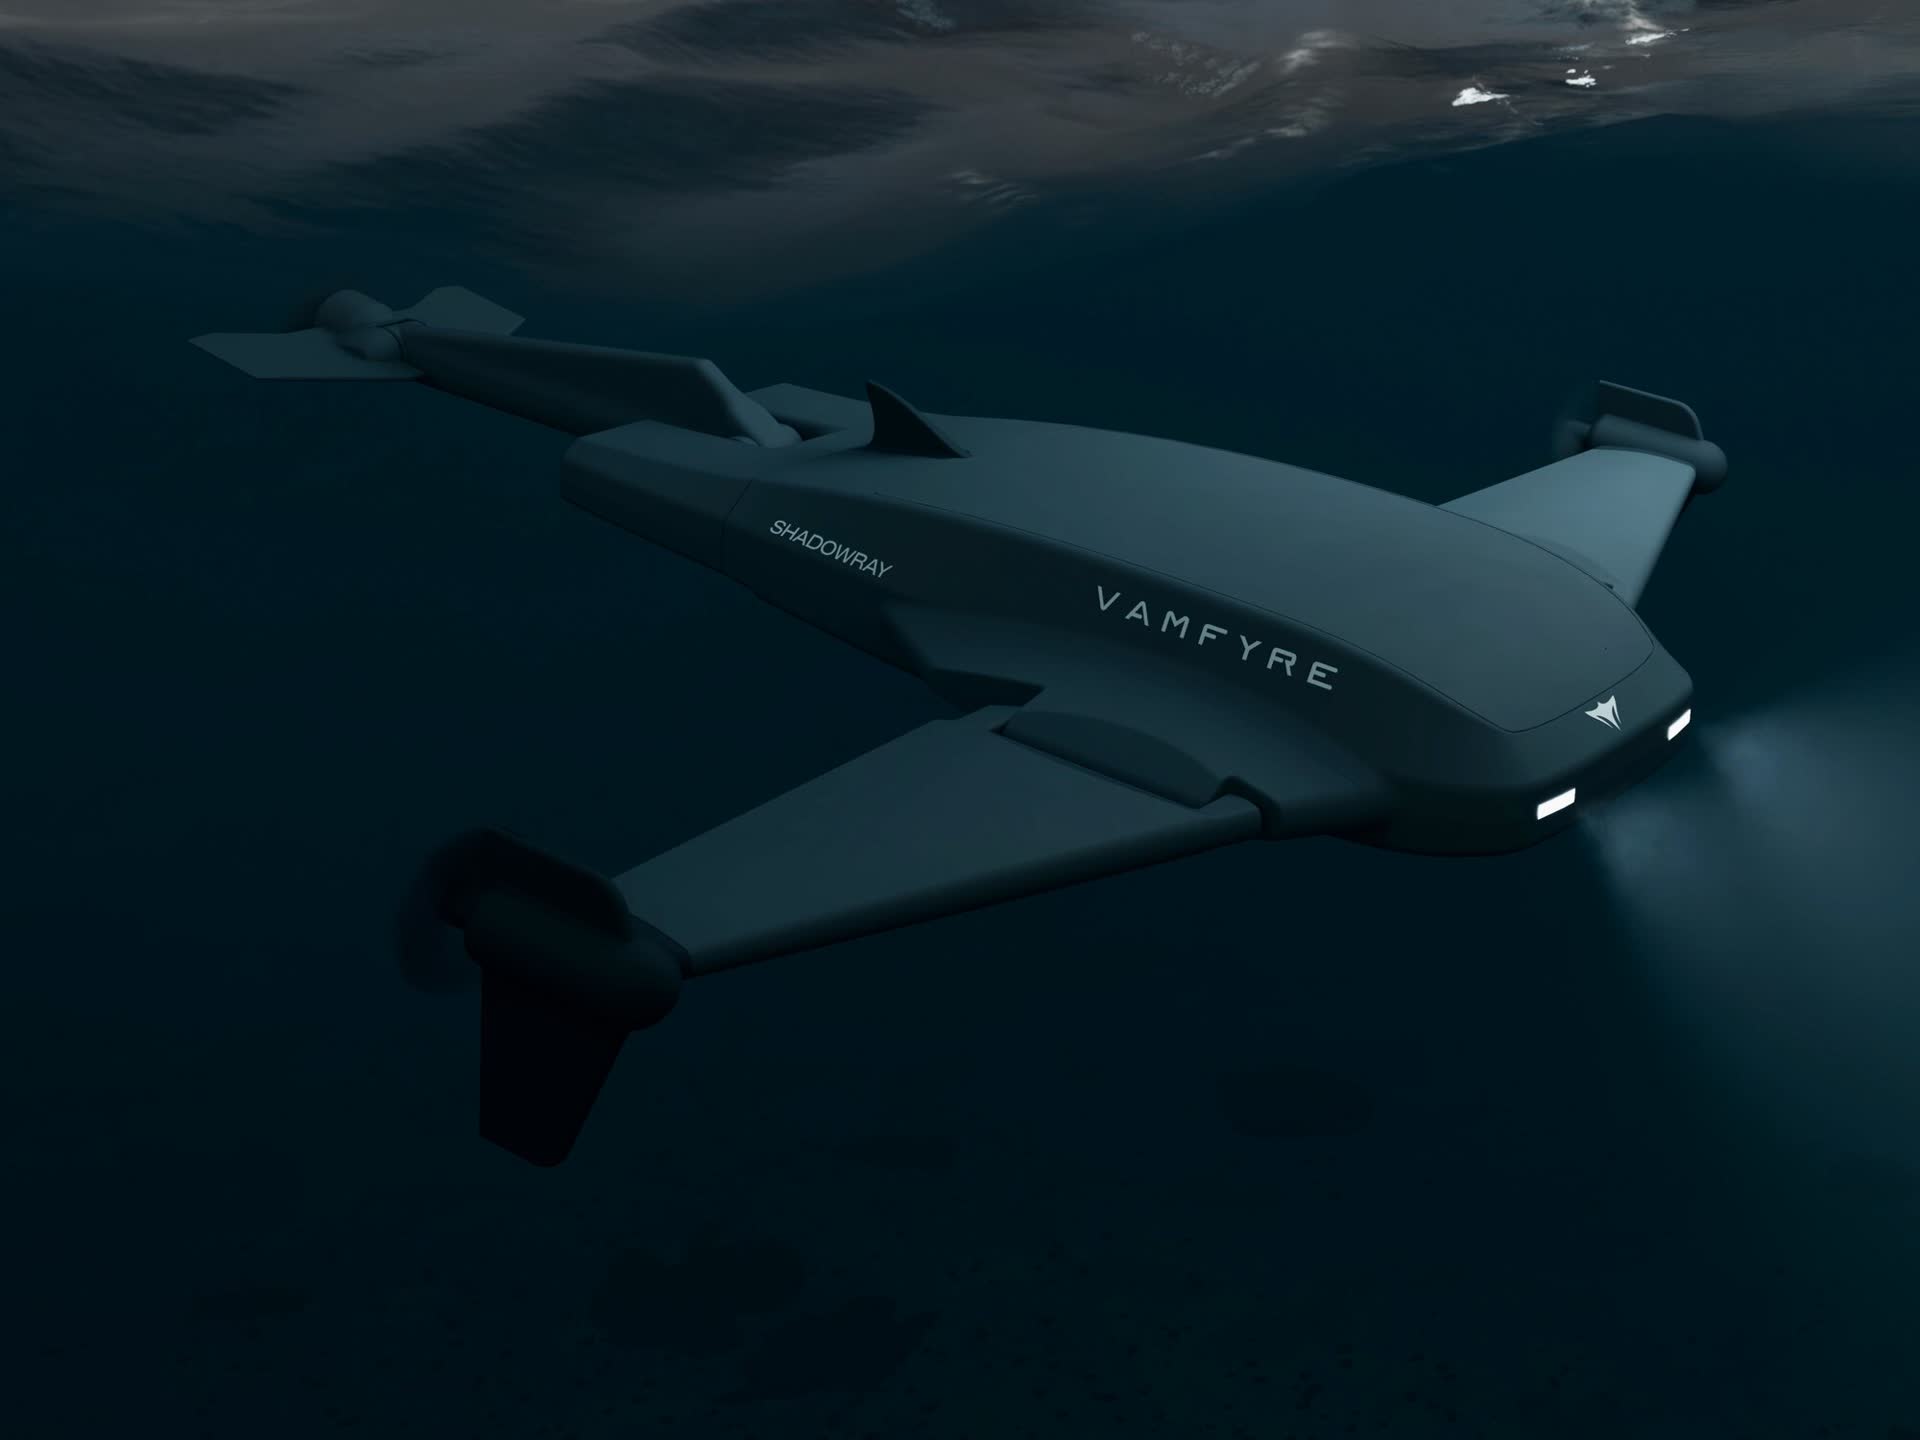
ShadowRay is designed to work on the surface, lift onto hydrofoils for high-speed transit, and dive to operate below, all in one 5 m electric hull, moving between the three within a single mission. We know of no other vessel designed to do all three.
Surface
Holds station, launches and recovers, and senses from the surface like a conventional uncrewed vessel.
Foiling
Lifts the hull clear of the waves on hydrofoils to cover distance at speed.
Submerged
Dives to transit quietly and sense below the surface, then surfaces to report.
In developmentPersistent surface presence.
Solar and wave energy harvesting, designed to keep a 2.2 m sensing and relay node on station.
- Role
- Persistent surface presence, surveillance, and communications relay.
- Energy
- Electric propulsion with solar and wave energy harvesting.
- Sensing
- Cameras and navigation sensors, with further sensors selected by mission.
- At sea
- The intended launch platform for ShadowHawk.
In developmentEyes above the horizon.
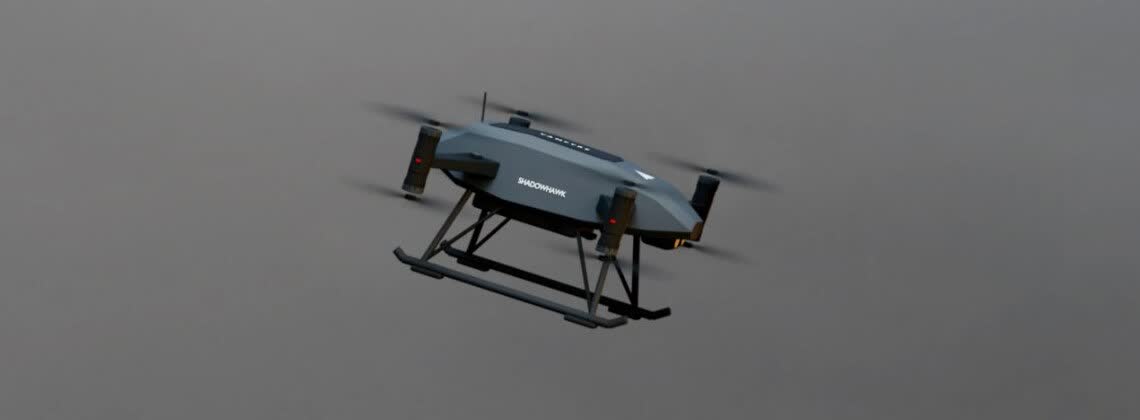
An extended surveillance drone designed to give the fleet a wide view from above, searching and identifying across the operating area. Intended to launch from ShadowDart at sea.
Next
One operator. The whole fleet.
Every vehicle is designed to be tasked and coordinated through POSEIDON.
POSEIDON